/01Launch · parts ordered
Precision sprayer
Doses pesticide and fertiliser down greenhouse rows and small plots where tractors can't fit. Nozzles switch one by one, so a plant flagged as diseased is sprayed and its healthy neighbour is not.
 Backed by UzCombinator
Robot built to do both on its own: precise doses where they are needed, and a camera that watches for disease.
Presented at
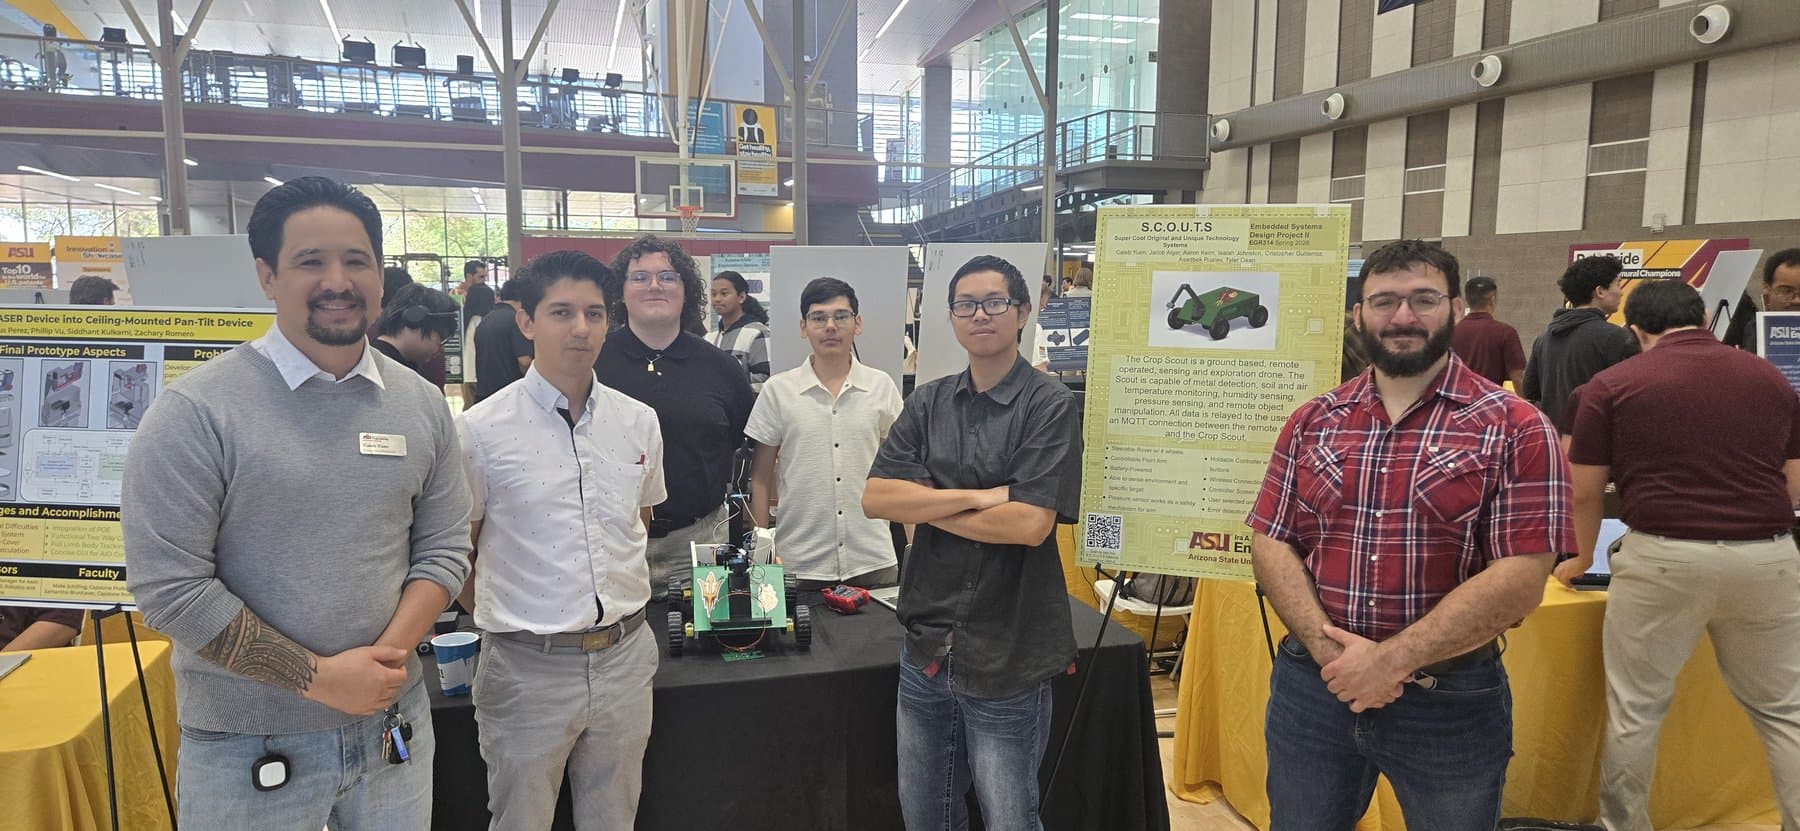
ASU Fulton Innovation ShowcaseSpring 2026
Awarded
USAID agri-innovation contest2nd place
Built at
HackHarvard1st place
The robot
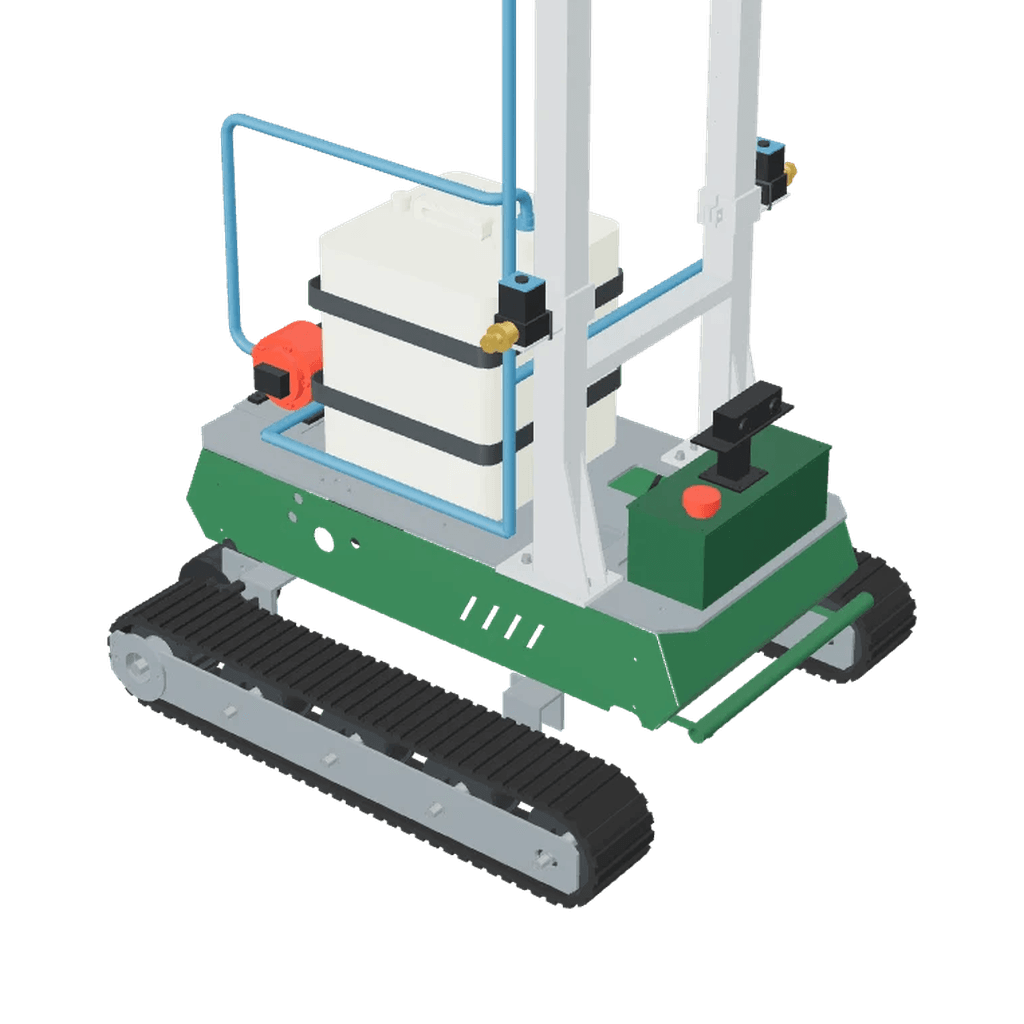
A tracked base sized for greenhouse rows and wet soil. Every tool mounts to the same top plate, so one robot grows into the farm's platform step by step.
Doses pesticide and fertiliser down greenhouse rows and small plots where tractors can't fit. Nozzles switch one by one, so a plant flagged as diseased is sprayed and its healthy neighbour is not.
A camera and sensors track plant health, disease signs and growth, and report to the farmer's phone. The vision models are being retrained on real field photos, tomato and cucumber first.
Automated weeding on the same base: the job farmers named most often as their biggest time cost.
Field research
We interviewed farmers in Jizzakh, Surkhandarya and Shakhrisabz in July and August 2026, before settling the design. The results are published in full, including the answers that argue against us.
30
Farmers interviewed
14/ 30
Weeding is their biggest time cost
12/ 30
Can't find seasonal labour
18/ 30
Picked the universal robot as helpful
“When we spray by hand, more than the norm ends up on the crop. […] If every plant got the same exact dose, no chemical would be wasted, and it wouldn't be a risk to the people who eat it.”
“If we take electric robots out to the fields and there's no power out there, how would I charge them?”
“It would be good if spare parts were easy to find, service were close by, and the price were affordable for farmers.”
Roadmap
2026
DoneA four-wheel rover with seven custom PCBs, demoed at the ASU Fulton Innovation Showcase. Then 30 farmer interviews, which told us to build bigger.
Fall 2026
DoneThe first browser version of the crop-vision tool, built at HackHarvard.The tracked V3 base modelled and frozen in SolidWorks.
Winter 2026
In progressUndercarriage, sprayer and onboard compute, built at ASU Polytechnic.
2027
NextOn real plots. The first number we owe farmers is the one they asked for: how many sotix an hour it covers.
We're building the V2 at ASU Polytechnic and start pilots in November 2026. Farmers, partners and investors: get in touch for a demo.